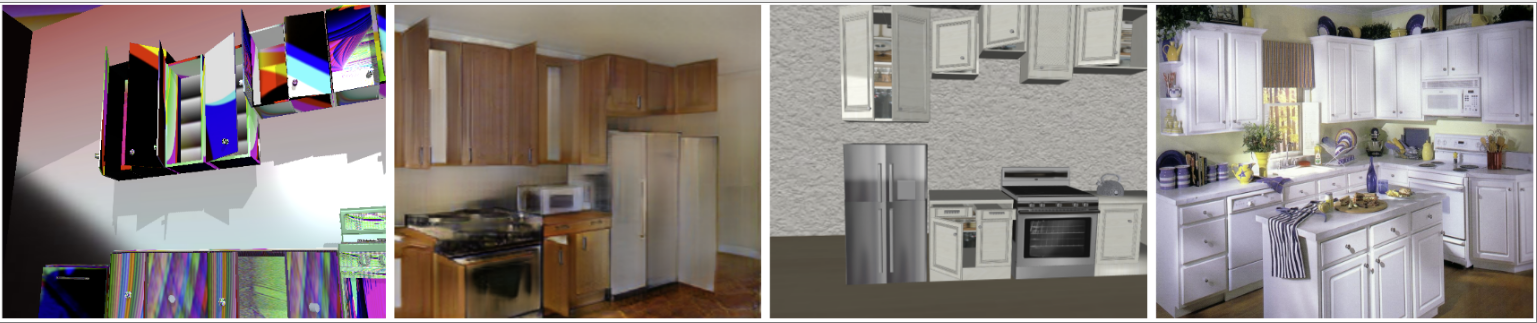
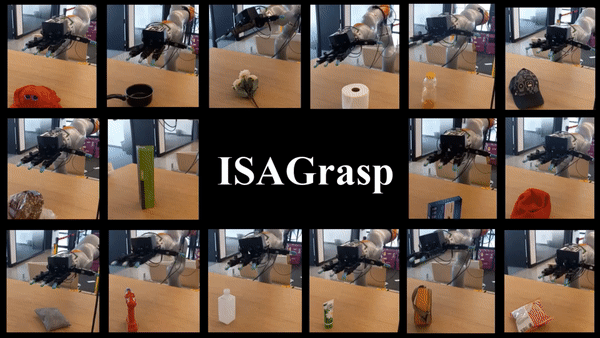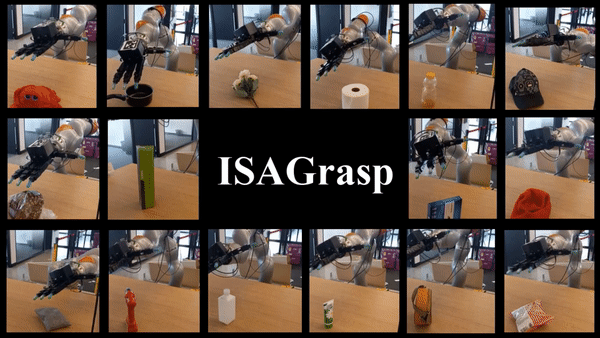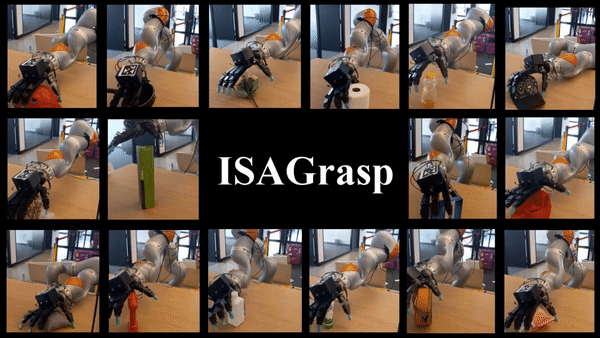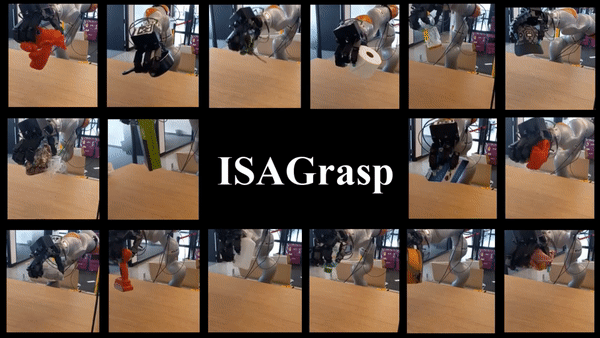
work Dexterous Grasping Can a robot learn from humans with only a few examples? Residual RL Can a better action representation help an RL policy learn from fewer samples? Sim2Real An earlier exploration of generative image translation for simulation-to-real transfer. Medical Image Analysis Reconstruction of blood vessels from stereo X-ray images. Implicit Shape Augmentation Generate novel shapes and ways to grasp them given minimal human demonstrations.